ΑΙhub.org
Trotting robots offer insights into animal gait transitions
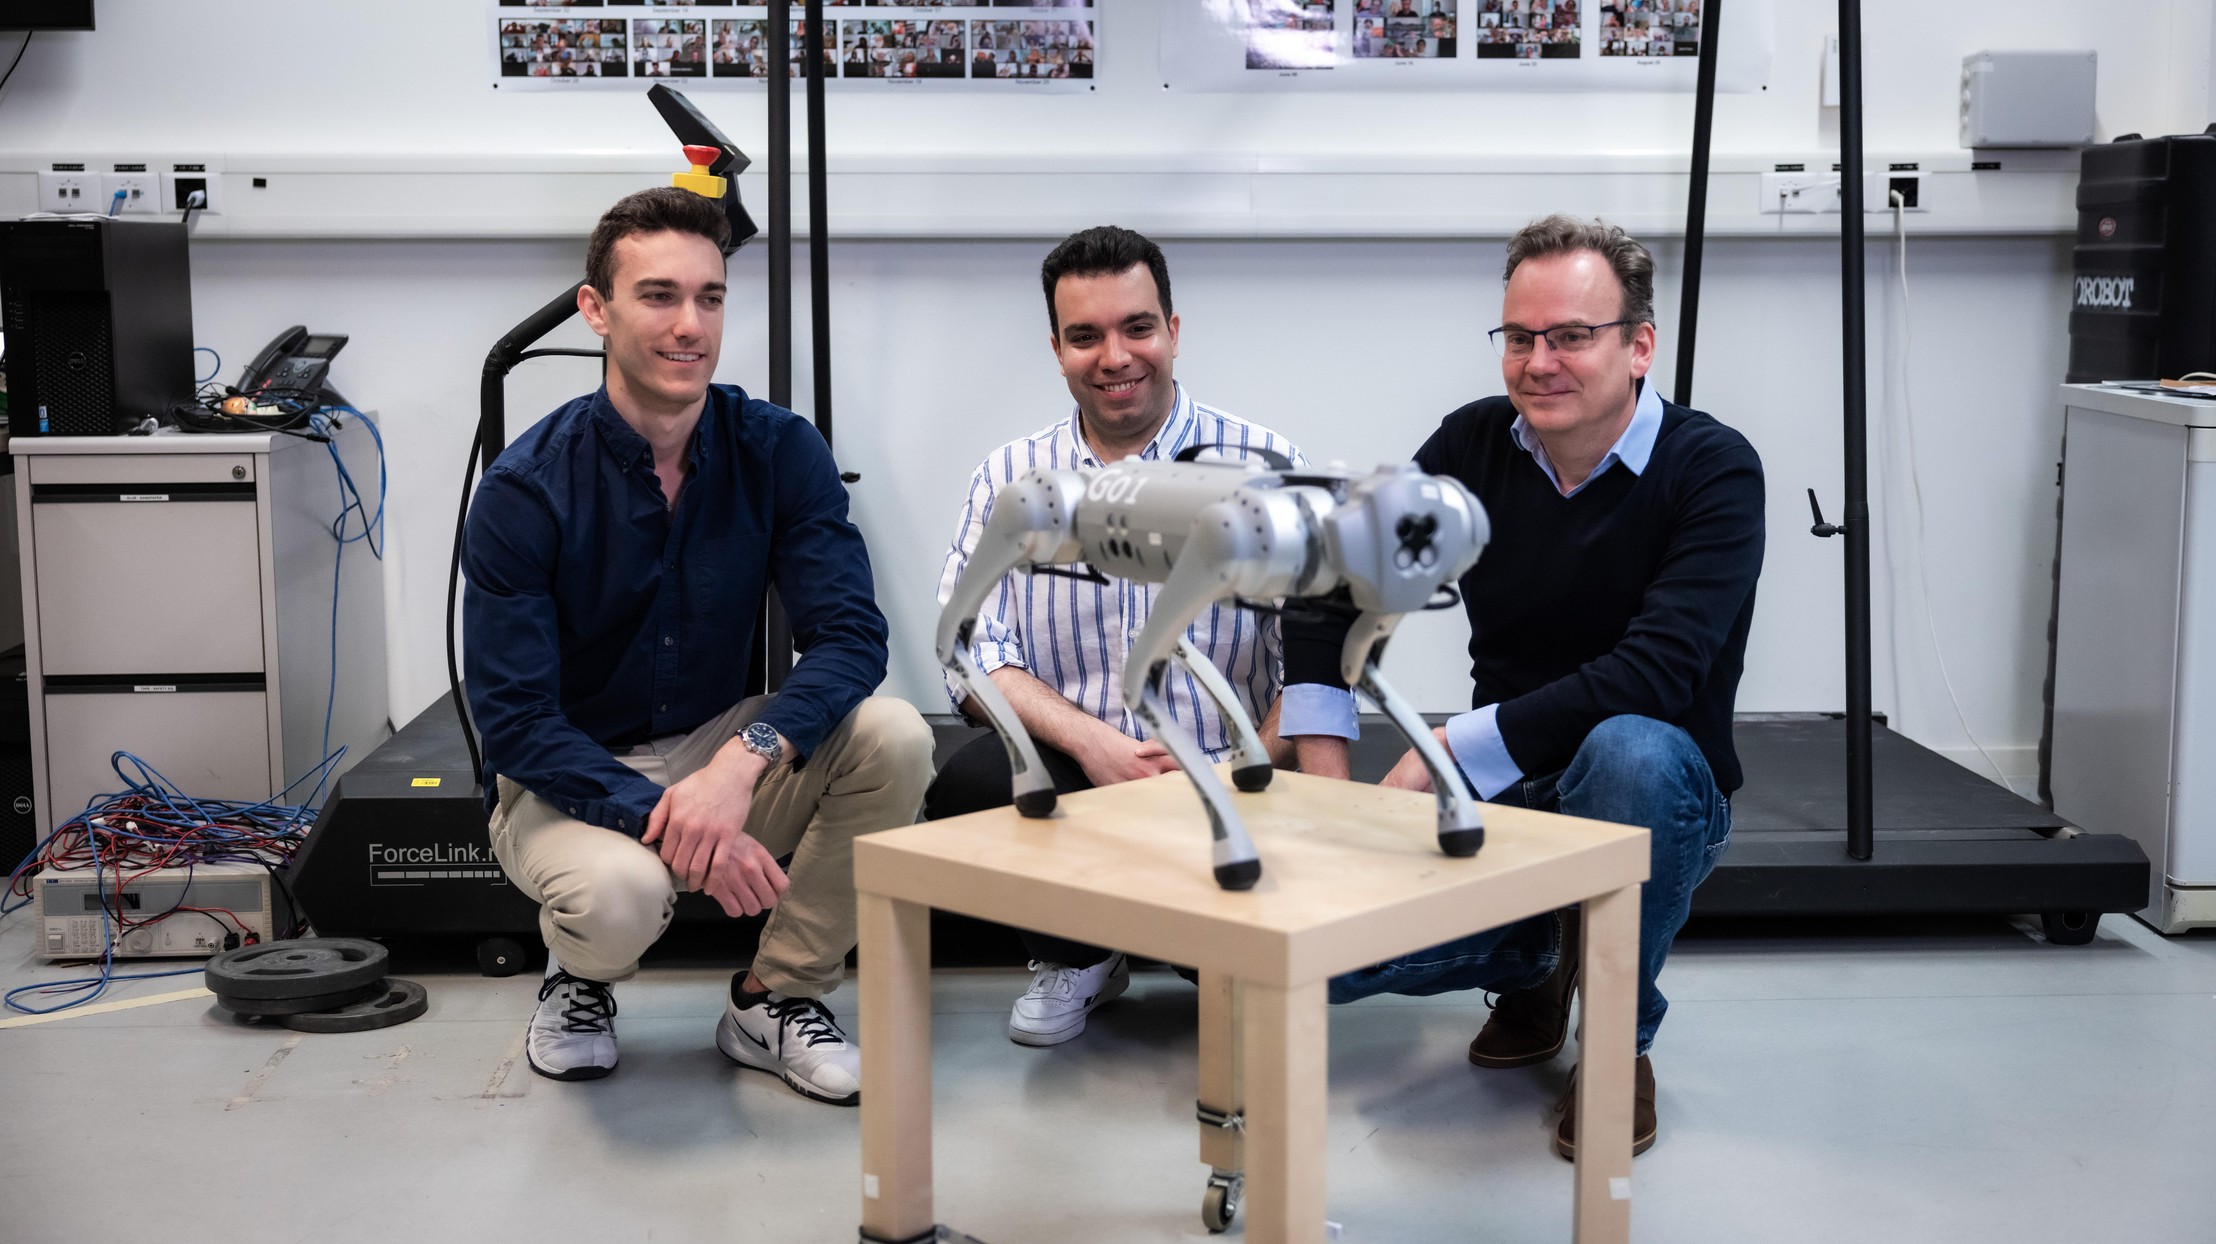 Guillaume Bellegarda, Milad Shafiee and Auke Ijspeert. 2024 EPFL/Jamani Caillet – CC-BY-SA 4.0
By Celia Luterbacher
A four-legged robot trained with machine learning by EPFL researchers has learned to avoid falls by spontaneously switching between walking, trotting, and pronking – a leaping, arch-backed gait used by animals like springbok and gazelles. With the help of a form of machine learning called deep reinforcement learning (DRL), the EPFL robot notably learned to transition from trotting to pronking to navigate a challenging terrain with gaps ranging from 14-30cm. The study, led by the BioRobotics Laboratory in EPFL’s School of Engineering, offers new insights into why and how such gait transitions occur in animals.
“Previous research has introduced energy efficiency and musculoskeletal injury avoidance as the two main explanations for gait transitions. More recently, biologists have argued that stability on flat terrain could be more important. But animal and robotic experiments have shown that these hypotheses are not always valid, especially on uneven ground,” says PhD student Milad Shafiee, first author on a paper published in Nature Communications.
Shafiee and co-authors Guillaume Bellegarda and BioRobotics Lab head Auke Ijspeert were therefore interested in a new hypothesis for why gait transitions occur: viability, or fall avoidance. To test this hypothesis, they used DRL to train a quadruped robot to cross various terrains. On flat terrain, they found that different gaits showed different levels of robustness against random pushes, and that the robot switched from a walk to a trot to maintain viability, just as quadruped animals do when they accelerate. And when confronted with successive gaps in the experimental surface, the robot spontaneously switched from trotting to pronking to avoid falls. Moreover, viability was the only factor that was improved by such gait transitions.
“We showed that on flat terrain and challenging discrete terrain, viability leads to the emergence of gait transitions, but that energy efficiency is not necessarily improved,” Shafiee explains. “It seems that energy efficiency, which was previously thought to be a driver of such transitions, may be more of a consequence. When an animal is navigating challenging terrain, it’s likely that its first priority is not falling, followed by energy efficiency.”
A bio-inspired learning architecture
To model locomotion control in their robot, the researchers considered the three interacting elements that drive animal movement: the brain, the spinal cord, and sensory feedback from the body. They used DRL to train a neural network to imitate the spinal cord’s transmission of brain signals to the body as the robot crossed an experimental terrain. Then, the team assigned different weights to three possible learning goals: energy efficiency, force reduction, and viability. A series of computer simulations revealed that of these three goals, viability was the only one that prompted the robot to automatically – without instruction from the scientists – change its gait.
The team emphasizes that these observations represent the first learning-based locomotion framework in which gait transitions emerge spontaneously during the learning process, as well as the most dynamic crossing of such large consecutive gaps for a quadrupedal robot.
“Our bio-inspired learning architecture demonstrated state-of-the-art quadruped robot agility on the challenging terrain,” Shafiee says.
The researchers aim to expand on their work with additional experiments that place different types of robots in a wider variety of challenging environments. In addition to further elucidating animal locomotion, they hope that ultimately, their work will enable the more widespread use of robots for biological research, reducing reliance on animal models and the associated ethics concerns.
Read the work in full
Viability leads to the emergence of gait transitions in learning agile quadrupedal locomotion on challenging terrains, Milad Shafiee, Guillaume Bellegarda & Auke Ijspeert, (2024).
AUAI is supported by: